Coinft is robust in the compressive direction
CoinFT Applications
Dexterous Manipulation
In-the-Wild Compliant Manipulation with UMI-FT
CoinFTs on each finger of a modified UMI device is used to collect multimodal data and perform compliance control on both external contact forces and internal grasp forces during manipulation.
Project WebsiteDexForce: Extracting Force-informed Actions from Kinesthetic Demonstrations for Dexterous Manipulation
CoinFTs are mounted on the fingers of a dexterous hand and are used to teach robots forceful dexterous manipulation through kinesthetic teaching.
Project Website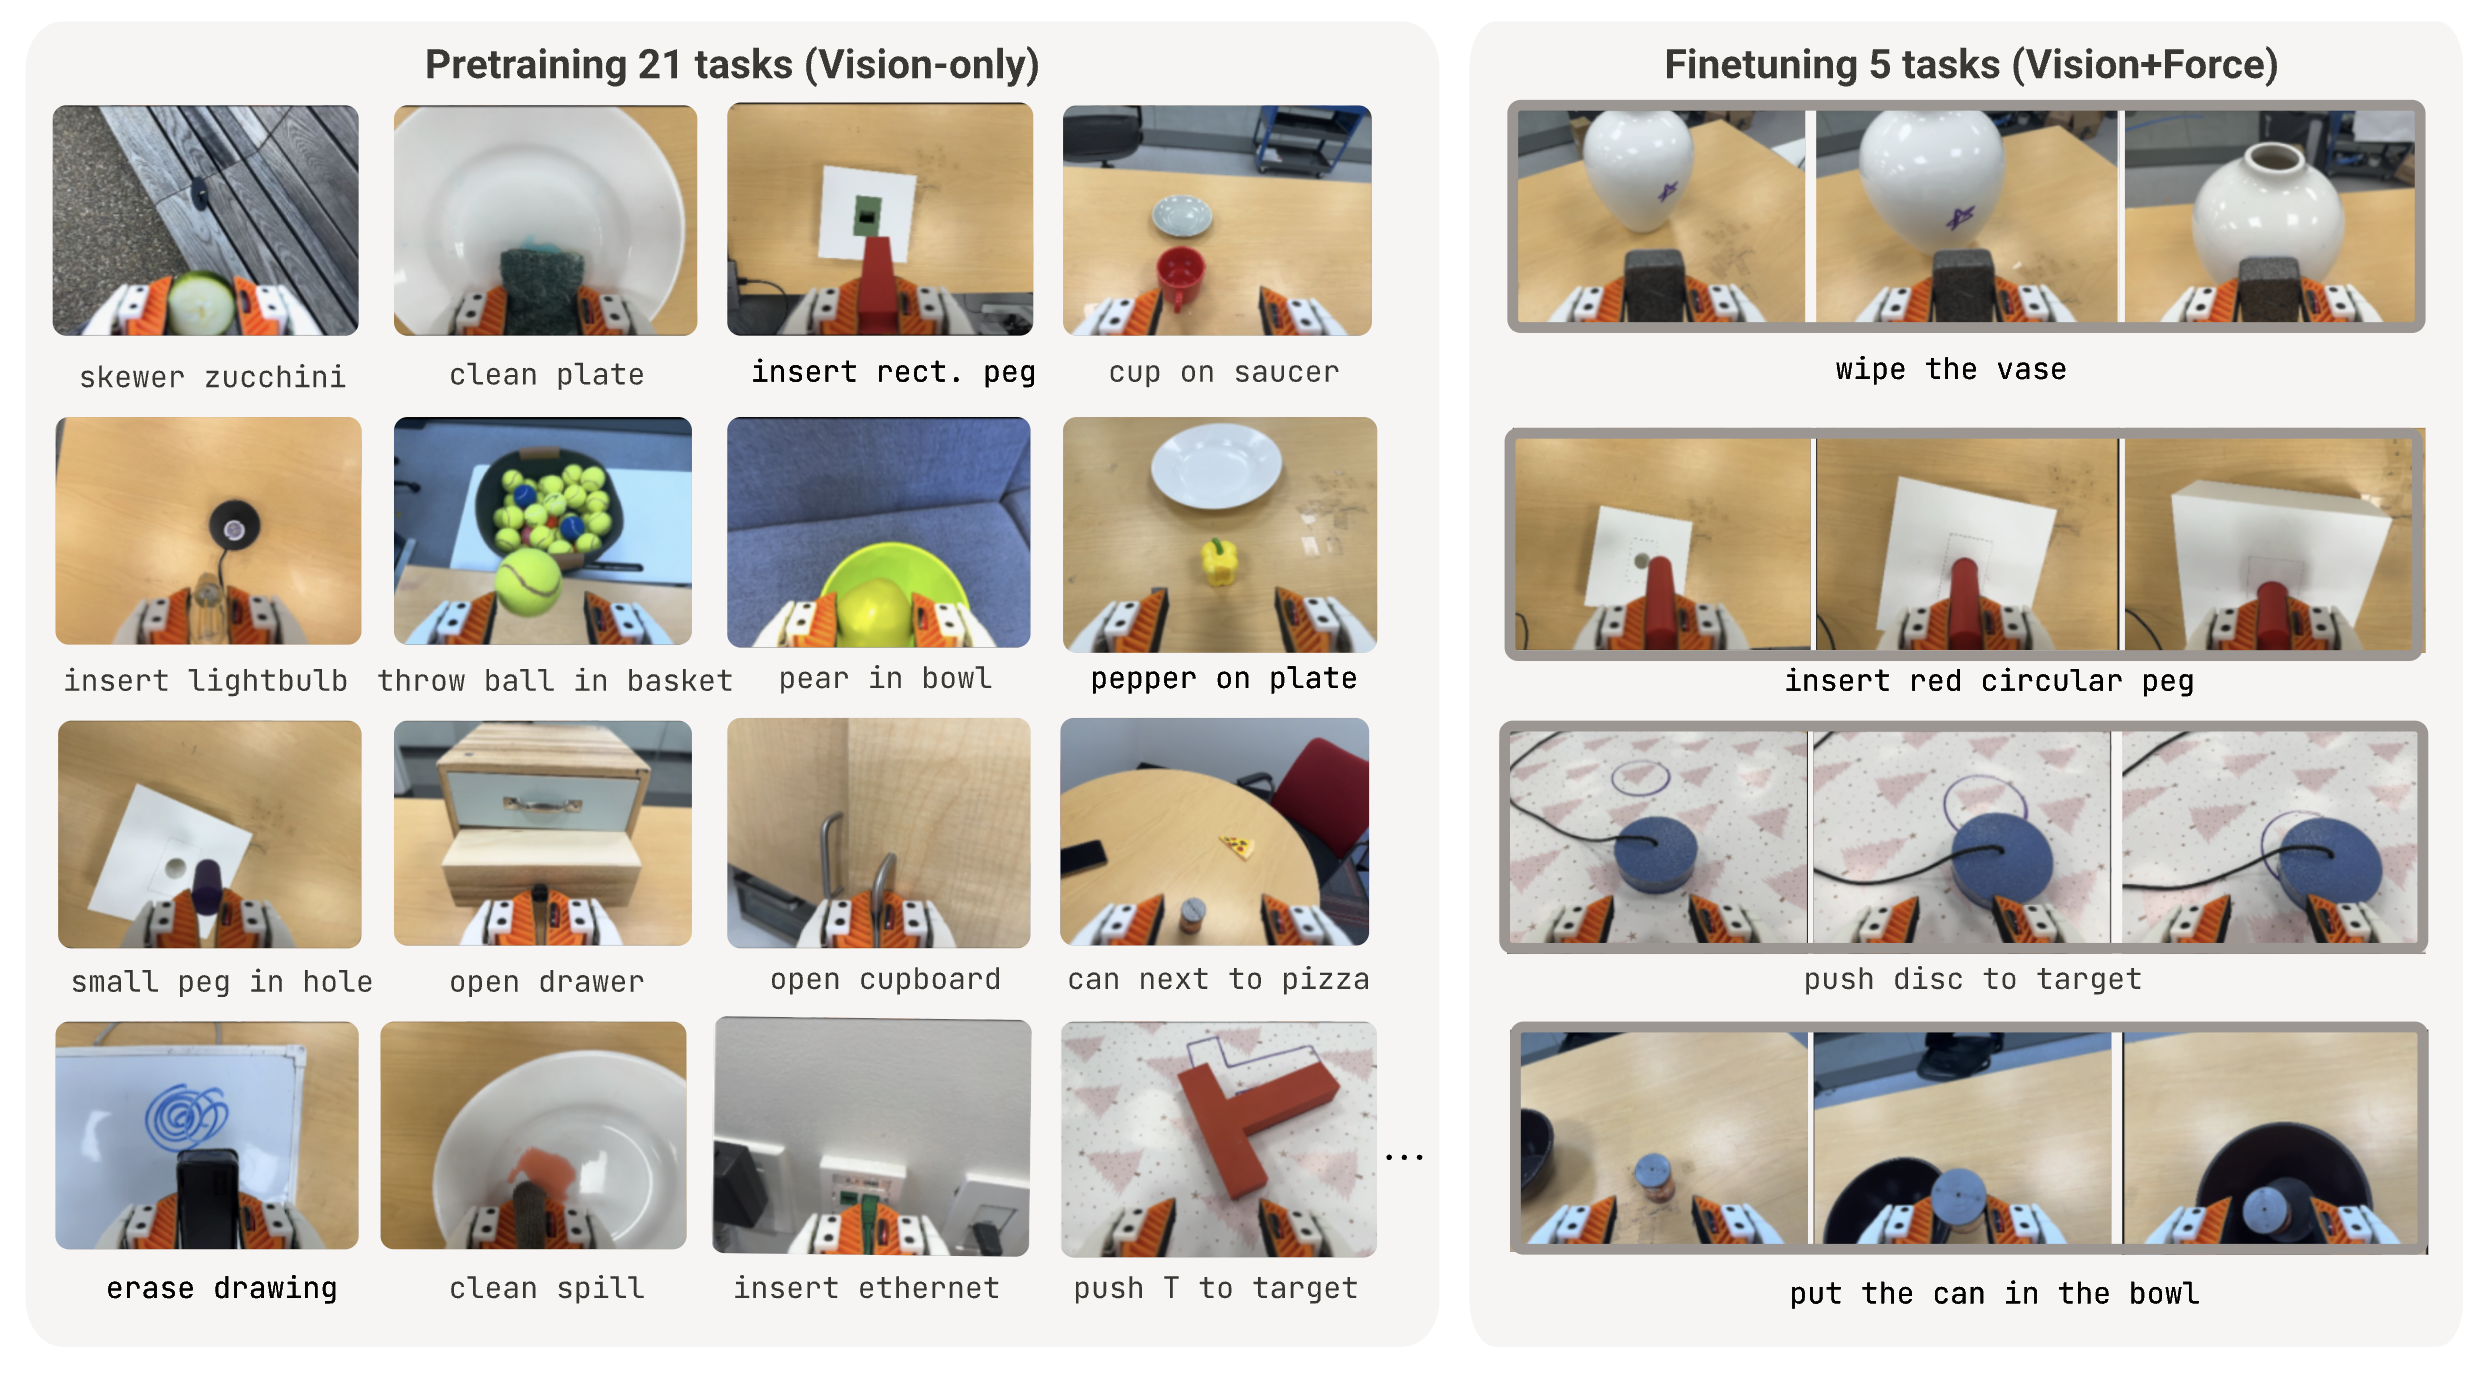
Multisensory Continual Learning: Adapting Pretrained Visuomotor Policies to Force
CoinFT provides the force/torque signals that MuSe uses to add force as a new modality to pretrained visuomotor policies during finetuning, improving contact-rich tasks such as wiping and peg insertion while retaining pretrained skills.
Project WebsiteDrones
Contact Force Control of Aerial Vehicles
A attitude-based force PID control enables aerial vehicles to regulate contact force using CoinFT, allowing drones to perform contact-based tasks reliably.
Wearable Devices
Fourigami: A 4-Degree-of-Freedom, Force-Controlled, Origami, Finger Pad Haptic Device
A 4-DoF fingertip haptic device can provide force-controlled haptic feedback using CoinFT.
Paper
Perceived Intensities of Normal and Shear Skin Stimuli using a Wearable Haptic Bracelet
CoinFT is used to compare intensity perception of normal and shear forces through a haptic bracelet.
PaperDesign and Evaluation of a 3-DoF Haptic Device for Directional Shear Cues on the Forearm
A 3-DoF forearm-mounted haptic device can provide force-controlled haptic feedback using CoinFT.
PaperMedical Robotics
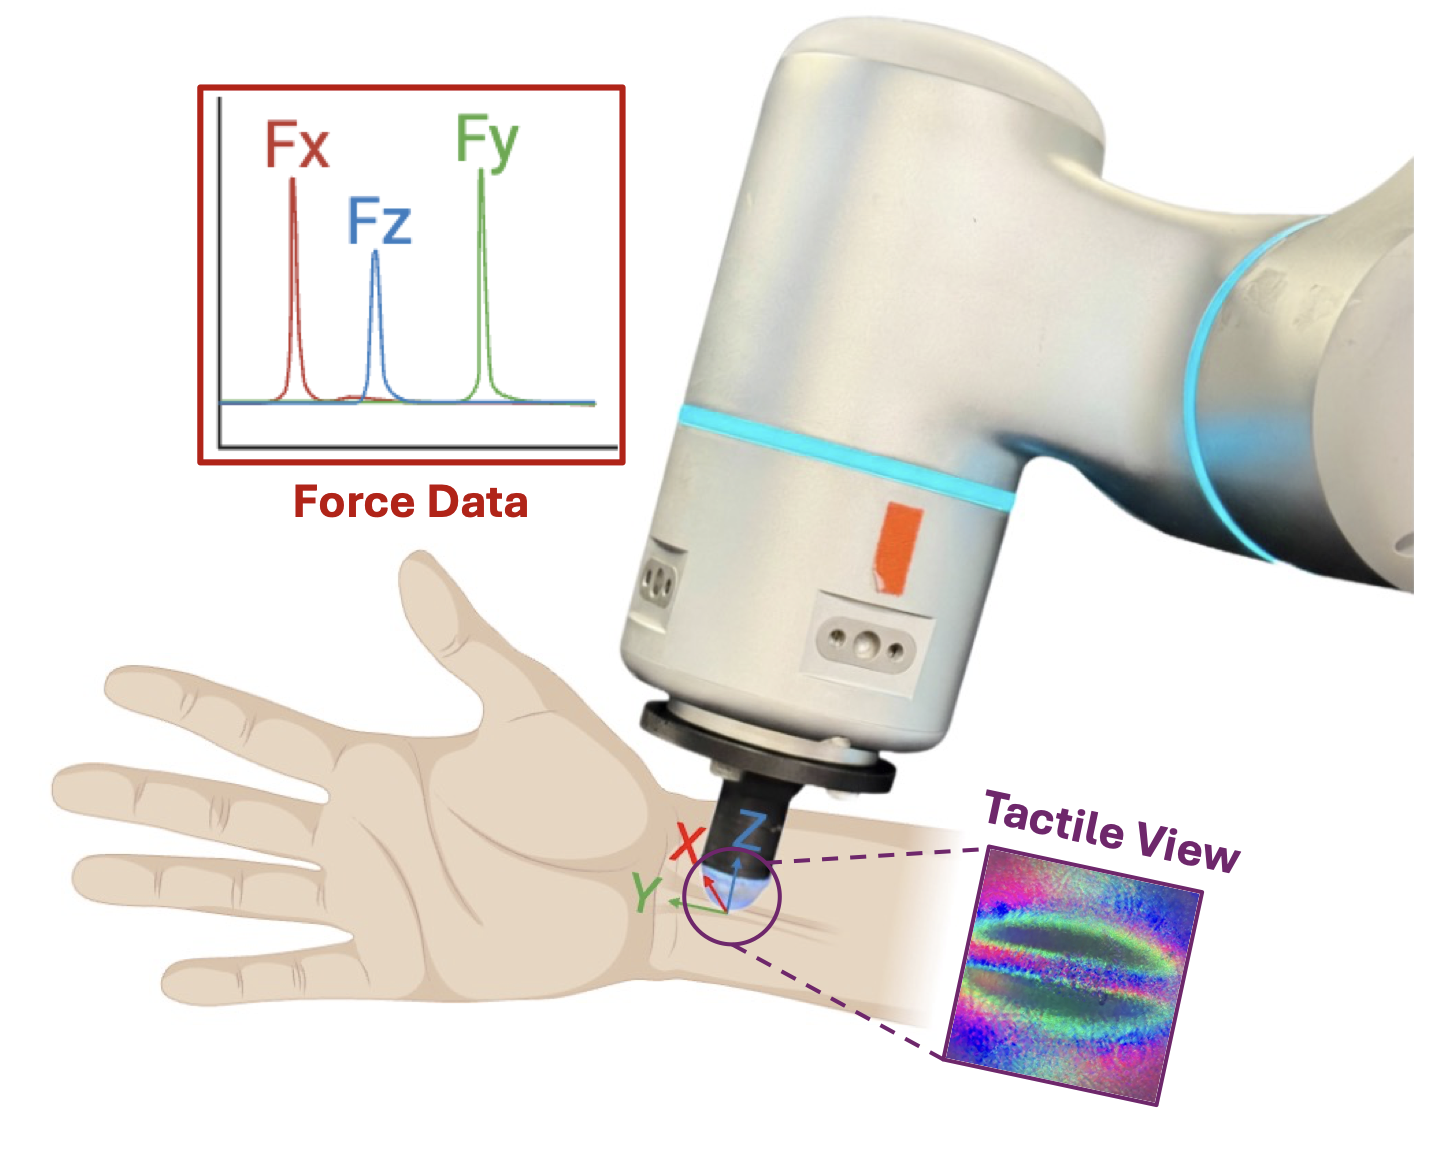
Multimodal Sensing for Robot-Assisted Sub-Tissue Feature Detection in Physiotherapy Palpation
PVFT pairs a vision-based tactile dome with CoinFT to capture tactile deformation and contact force simultaneously, enabling robotic palpation to detect subsurface tendon features under high loads.
Paper{Your Cool Project Here}
CoinFT Maintenance and Support
CoinFT continues to be researched and developed by Hojung Choi, Seongheon Hong, and Mark Cutkosky at the Biomimetics and Dexterous Manipulation Laboratory (BDML) at Stanford University.
For questions and feedback, please email Hojung (ilovehjb0520@gmail.com) and Seongheon (wbfprp@stanford.edu).
BibTeX
@misc{choi2025coinftcoinsizedcapacitive6axis,
      title={CoinFT: A Coin-Sized, Capacitive 6-Axis Force Torque Sensor for Robotic Applications},
      author={Hojung Choi and Jun En Low and Tae Myung Huh and Gabriela A. Uribe and Seongheon Hong and Kenneth A. W. Hoffman and Julia Di and Tony G. Chen and Andrew A. Stanley and Mark R. Cutkosky},
      year={2025},
      eprint={2503.19225},
      archivePrefix={arXiv},
      url={https://arxiv.org/abs/2503.19225}}